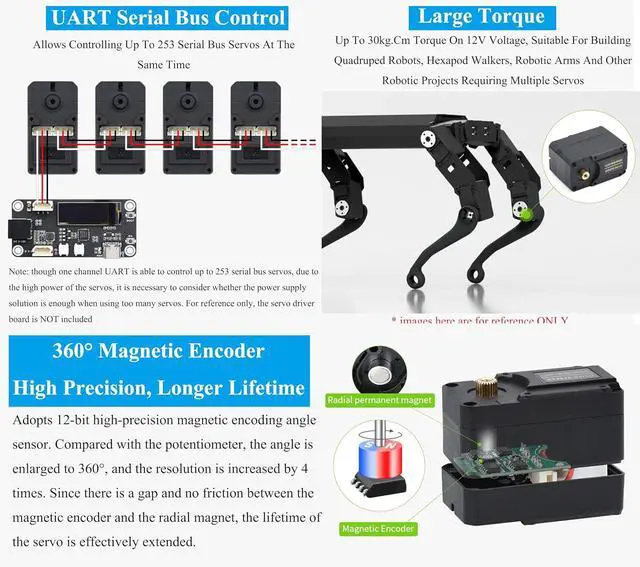
UART Serial Bus Control: Allows controlling up to 253 serial bus servos at the same time.
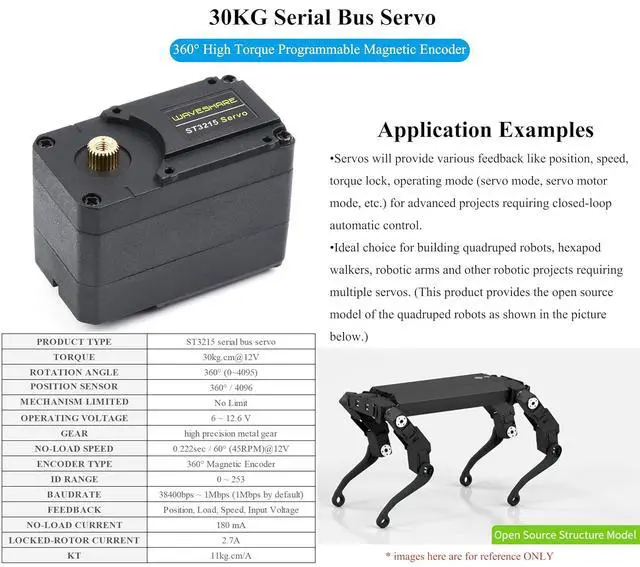
Large Torque: Up To 30kg. Cm Torque On 12V Voltage, Suitable For Building Quadruped Robots, Hexapod Walkers, Robotic Arms And Other Robotic Projects Requiring Multiple Servos.
360° Magnetic Encoder High Precision,
Longer Lifetime: Adopts 12-bit high-precision magnetic encoding angle sensor. Compared with the potentiometer, the angle is enlarged to 360°, and the resolution is increased by 4 times. Since there is a gap and no friction between the magnetic encoder and the radial magnet, the lifetime of the servo is effectively extended.
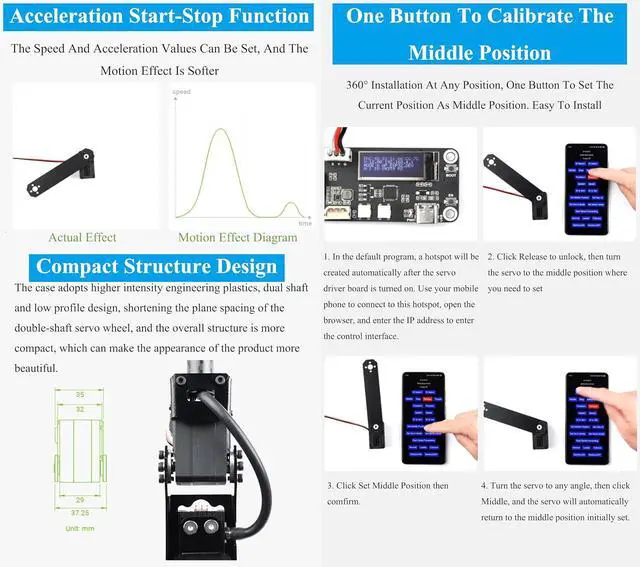
Acceleration Start-stop Function: The speed and acceleration values can be set, and the motion effect is softer. One Button to Calibrate the
Middle Position: 360° installation at any position, one button to set the current position as middle position. Easy to install.
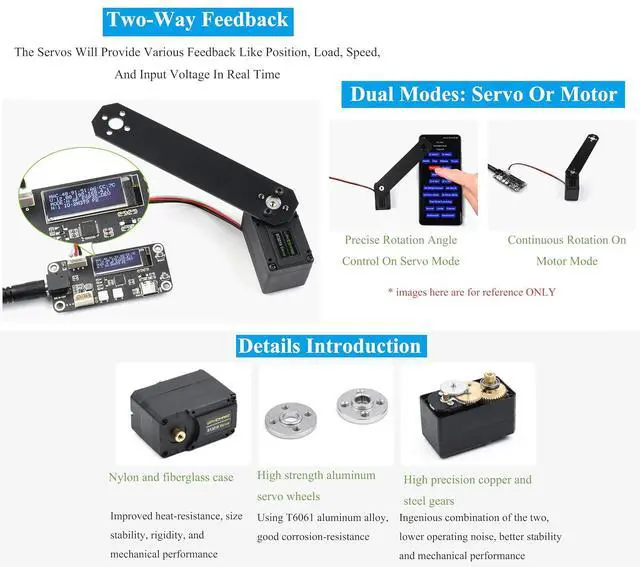
Two-Way Feedback: The Servos Will Provide Various Feedback Like Position, Load, Speed, And Input Voltage In Real Time.
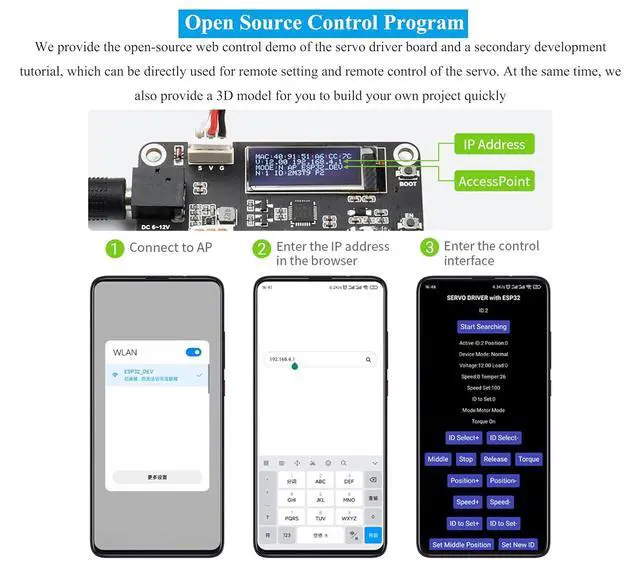
Open Source Control Program: We provide the open-source web control demo of the servo driver board and a secondary development tutorial, which can be directly used for remote setting and remote control of the servo. At the same time, we also provide a 3D model for you to build your own project quickly.


 All Categories