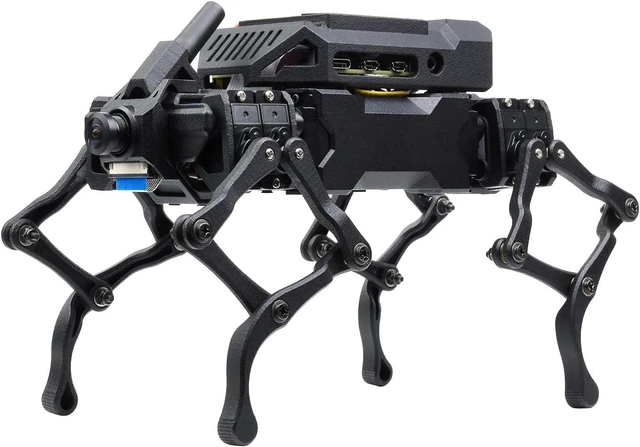
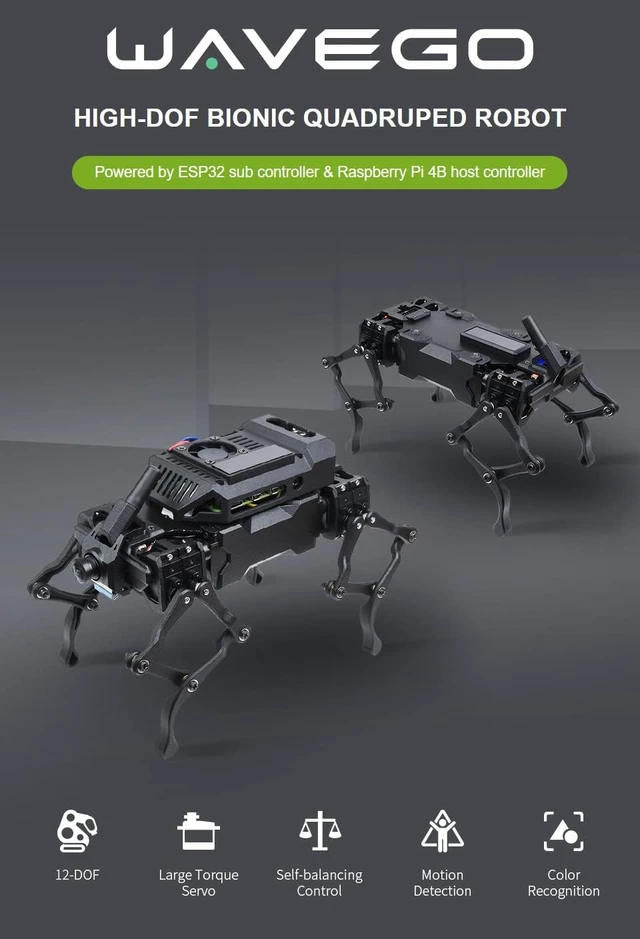
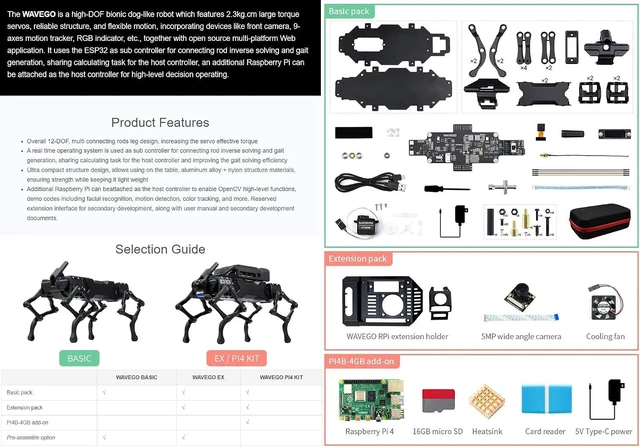
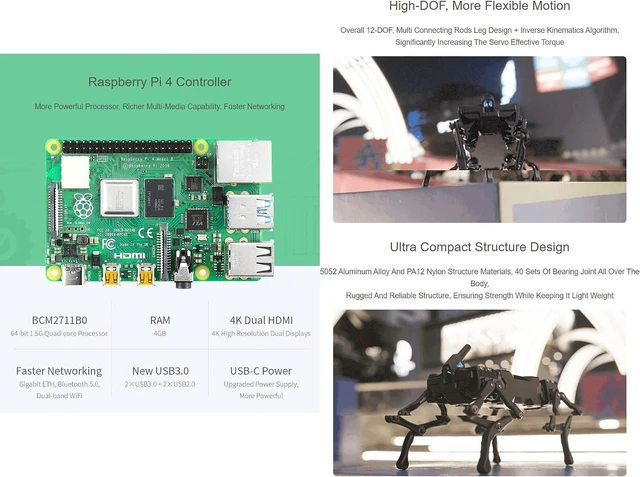
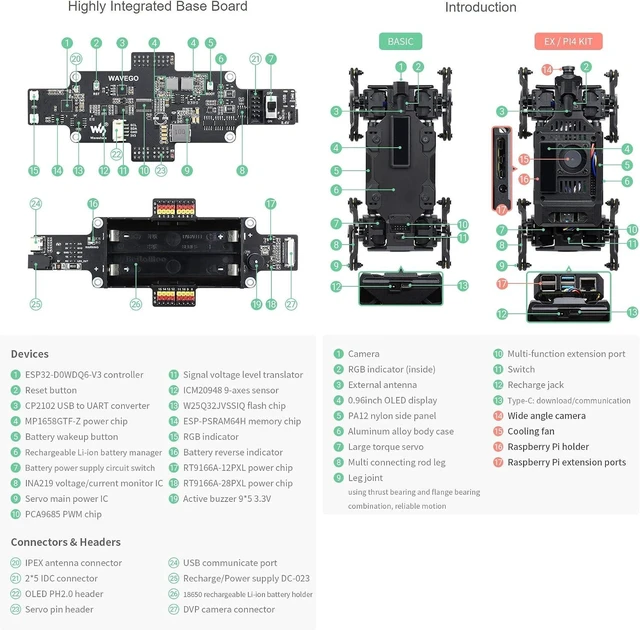
Overall 12-DOF, multi connecting rods leg design, increasing the servo effective torque
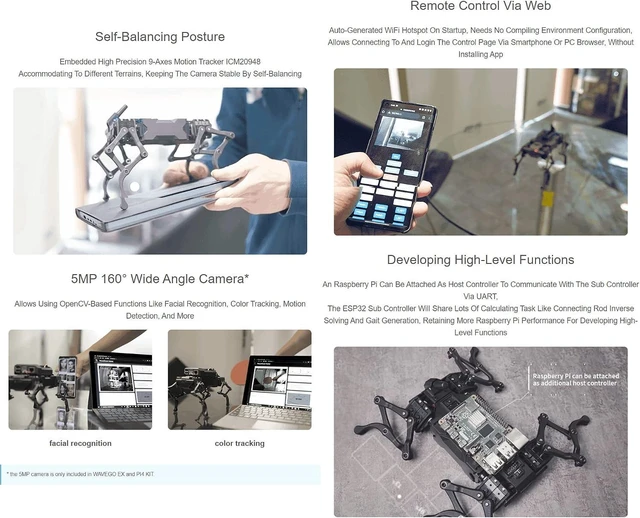
A real time operating system is used as sub controller for connecting rod inverse solving and gait generation, sharing calculating task for the host controller and improving the gait solving efficiency
Ultra compact structure design, allows using on the table, aluminum alloy + nylon structure materials, ensuring strength while keeping it light weight
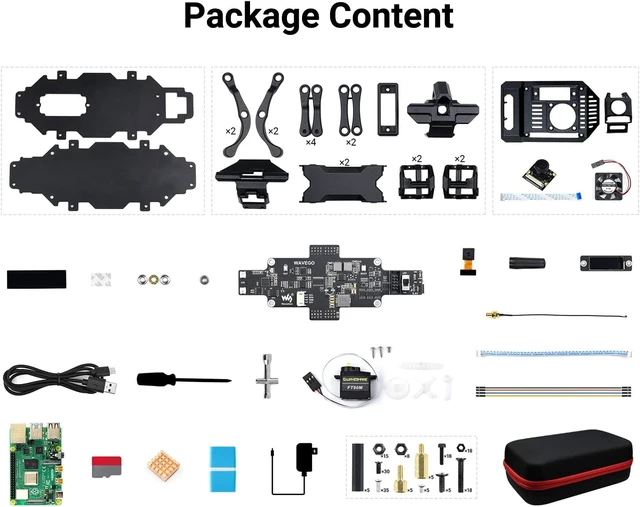
Additional Raspberry Pi can beattached as the host controller to enable OpenCV high-level functions, demo codes including facial recognition, motion detection, color tracking, and more.
Reserved extension interface for secondary development, along with user manual and secondary development documents.


 All Categories